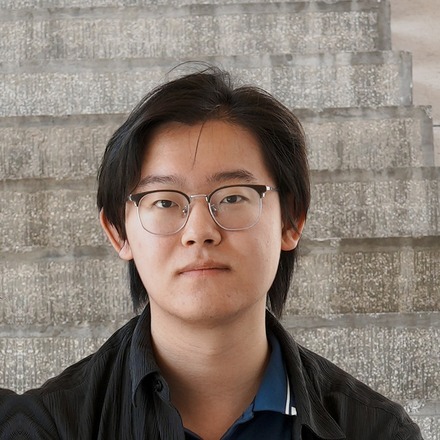
I am a Ph.D. student at Peking University.
I study simulation for robotic manipulation.
Education
-
Peking University — Ph.D., School of Software & Microelectronics
-
Peking University — B.S., School of Mathematical Sciences
During my internship at Shanghai AI Laboratory, I worked closely with Jiangmiao Pang and Jia Zeng.
Highlights
InternData-A1, the largest open-source synthetic dataset for robotic manipulation (630K trajectories, 7,433 hours), has been downloaded 550K+ times on Hugging Face and 1.65M+ times on ModelScope, and adopted by teams including NVIDIA Cosmos, ByteDance Seed, Qwen, Xiaomi, Tencent, JD, and Ant Lingbo to train their VLA and world models.
Seer (ICLR 2025 Oral) has served as a strong baseline for subsequent research on manipulation policies.
Built on the data and models above, the InternVLA series outperforms π0.5, π0, and GR00T N1.5 across real-robot and simulation benchmarks.
Selected publications
-
InternData-A1: Pioneering High-Fidelity Synthetic Data for Pre-training Generalist PolicyCVPR 2026 Isaac SimNewton
-
Seer: Predictive Inverse Dynamics Models are Scalable Learners for Robotic ManipulationICLR 2025 Oral (top 1.9%)
-
InternVLA-A1: Unifying Understanding, Generation and Action for Robotic ManipulationarXiv 2026
-
InternVLA-A1.5: Unifying Understanding, Latent Foresight, and Action for Compositional GeneralizationarXiv 2026
-
RoboKeyGen: Robot Pose and Joint Angles Estimation via Diffusion-based 3D Keypoint GenerationICRA 2024 Blender
-
Robot Structure Prior Guided Temporal Attention for Camera-to-Robot Pose Estimation from Image SequenceCVPR 2023 Blender
* equal contribution
Honors & awards
- 2026EAI-100 Next 20 Rising Star
- 2026EAI-100 Top 10 Dataset (InternData-A1)
- 2025Star Intern Award, the top intern award of Shanghai AI Laboratory
- 2019Top 15 in Shanghai College Entrance Examination (Gaokao)
Last updated: Sep 2026